DIFFIK-PANDA
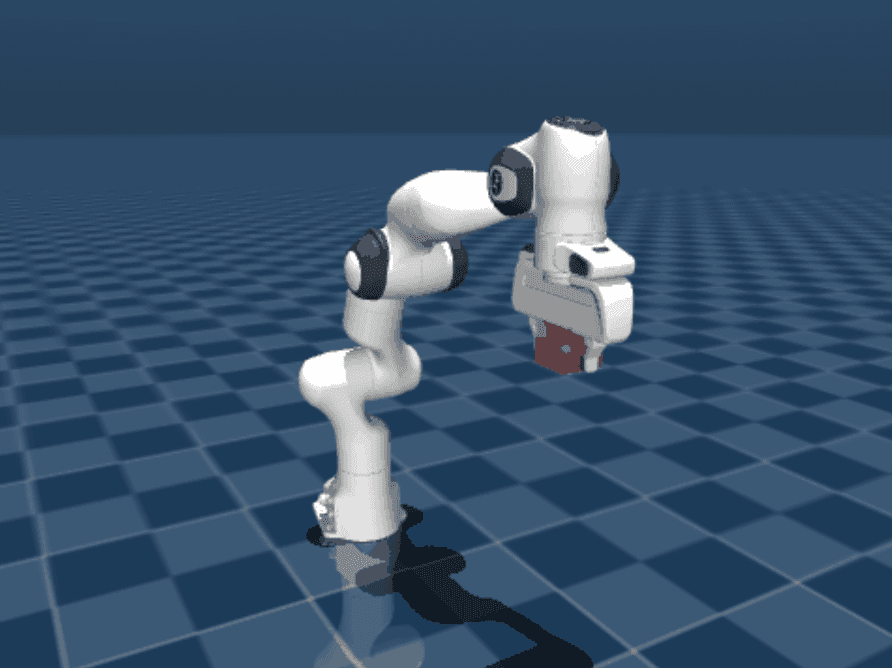
- A 6-DoF target is dragged through space, a damped least squares solver turns the pose error into joint velocity, and the arm tracks it until the Jacobian runs out of rank.
Inverse KinematicsMuJoCoRoboticsPython
- Status
- Research
- Date
- Aug 2026
- Role
- Researcher and Documentation
About
The target rides on a mocap body you can drag in the viewer. Every control step the solver computes a joint velocity that drives the end-effector site toward it, integrates that velocity into a position setpoint, and hands the setpoint to the position actuators. Where it gets interesting is the workspace boundary: the Jacobian loses rank as the arm straightens, and what the solver does there is the whole subject of this repository.